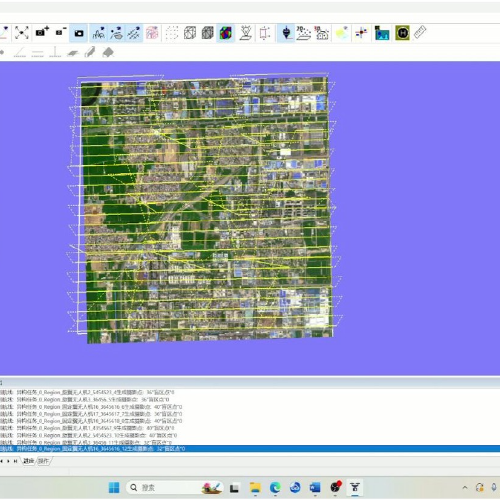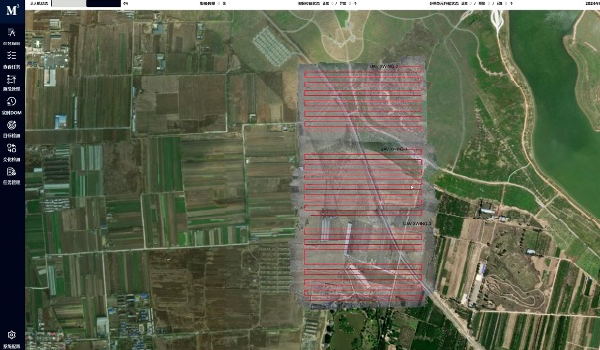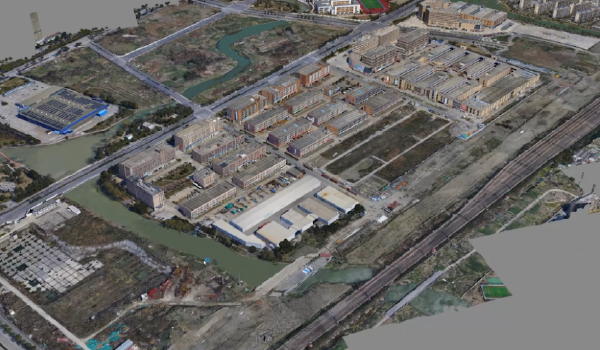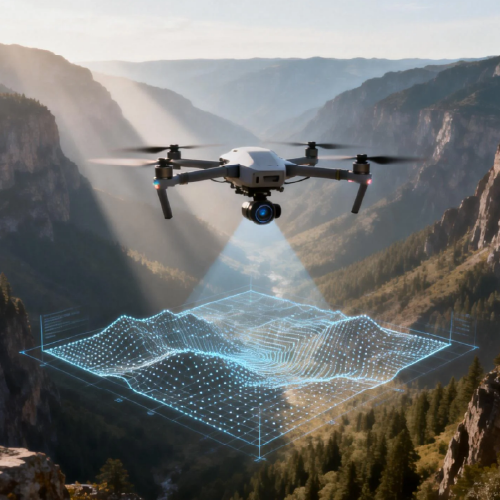
DroneSwarm is an edge-intelligent UAV cluster system engineered for precision drone data collection and real-time monitoring. It delivers: Multi-UAV collaborative real-time 2D/3D mapping.
Driven by two specialized lines, BeeSmart and Hunter Wing, DroneSwarm creates a unified reconnaissance-disposal-analysis operations ecosystem.
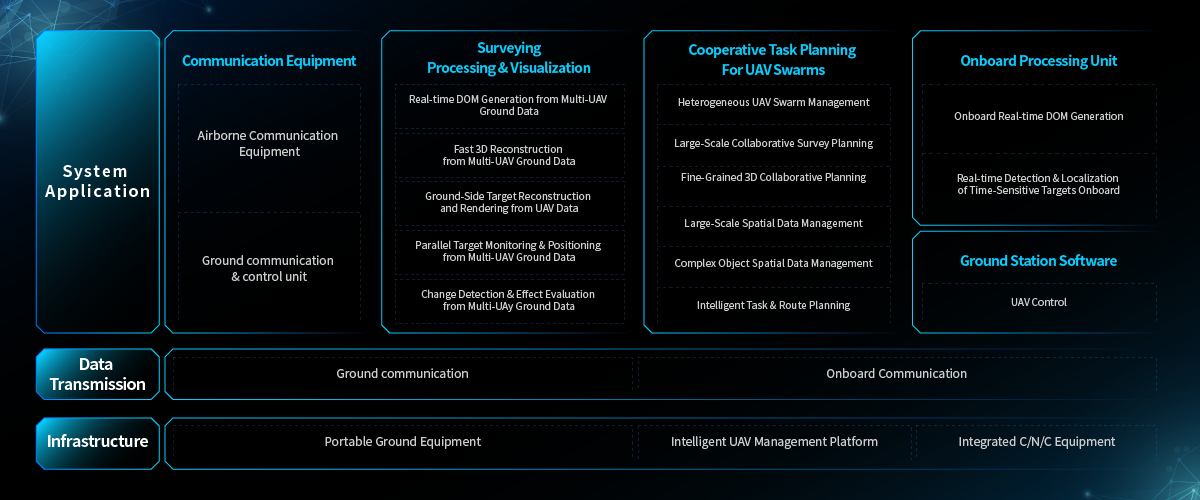
DroneSwarm combines real-time onboard processing with ground-side mission management in a robust multi-layer architecture for coordinated multi-UAV operations, enabling:


Heterogeneous Fleet Coordination — Supports coordinated deployment of multirotor, fixed-wing, and hybrid UAV platforms within the same mission environment.

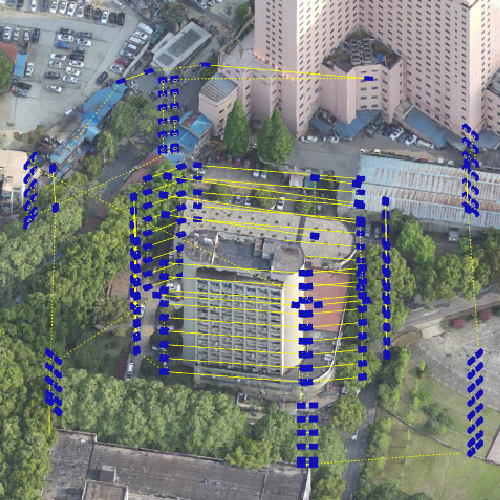
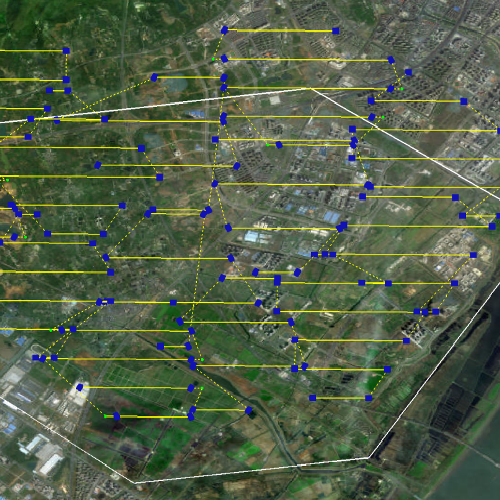
Dynamic Multi-UAV Path Planning — The planning engine generates flight routes based on UAV performance, terrain, and mission requirements, dynamically adjusting speed, altitude, and coverage density. It also supports mission re-planning and swarm reorganization when operating conditions change.

Large-Area Mapping Optimization — Automatically divides large survey areas according to terrain and UAV capability, while optimizing route overlap and task allocation to improve coverage efficiency across multi-UAV mapping missions.


DroneSwarm is designed around in-mission processing rather than a conventional capture-first, process-later workflow. The comparison below highlights the main differences between the two approaches.
| Dimension | Traditional Drone Mapping | DroneSwarm |
| Data Generation Timing | Raw footage stored for office-based post-processing | Drone data collection and DOM generation happen simultaneously in flight — no post-processing required |
| Communication Load | Transmits raw imagery, consuming full link bandwidth | Transmits only processed results via drone edge computing, reducing link load to 1% of traditional mode |
| Positioning Basis | Single-source GPS, prone to drift in signal-shadowed areas | GPS + visual SLAM fusion for UAV positioning, accuracy < 1× GSD |
| Tracking Continuity | Tracking interrupted when communication link drops | Dual-mode online/offline operation keeps UAV tracking active via cached imagery |
| Multi-UAV Coordination | Sequential, single-UAV missions planned manually | Multi-UAV path planning with dynamic re-planning and swarm re-grouping |
| Change / Output Analysis | Manual comparison across separate survey datasets | Automated multi-temporal DOM/3D comparison as part of drone data analytics, pixel-level accuracy over 95% |
| Decision Latency | Hours to days after landing | Minutes — suitable for real-time monitoring systems and time-sensitive decision-making. |
This comparison reflects the architecture described above: DroneSwarm doesn’t add real-time features to a traditional pipeline — it’s built so that collection, processing, and analysis happen as a single continuous loop in the air.
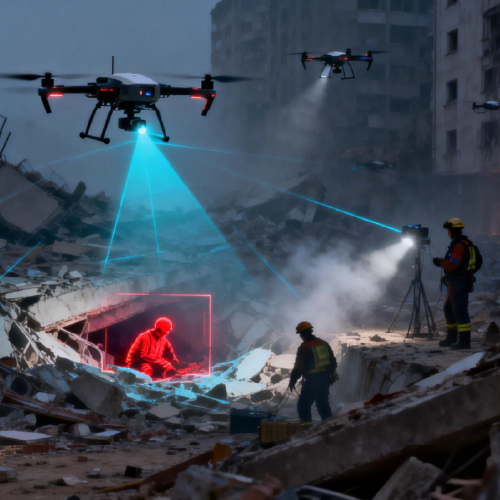
DroneSwarm supports large-area and time-sensitive missions where coordinated UAV operations, real-time spatial data, and onboard analysis can improve field awareness and response.

Coordinate heterogeneous UAV fleets for real-time terrain mapping, target tracking, and mission-level spatial awareness, with local processing available when external communication is limited.

Generate real-time maps, locate supported targets, and continue key processing functions during temporary communication interruptions to support situational assessment and field response.

Coordinate multi-UAV mapping across large areas, with optimized route overlap, high-precision spatial outputs, and multi-temporal data for surveying, mapping, and GIS update workflows.

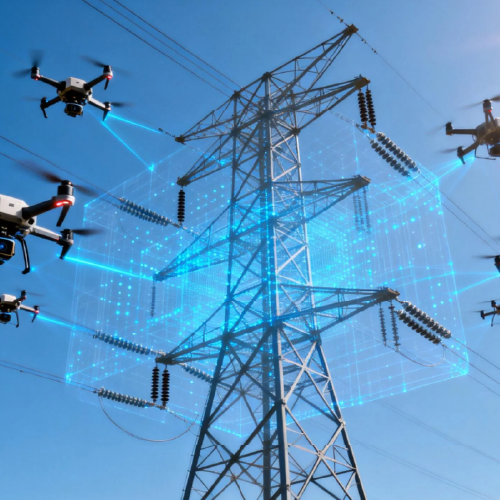
Support patrol and monitoring across large or difficult-to-access areas, together with 3D mapping and spatial analysis for energy and infrastructure inspection workflows.
While DroneSwarm’s core architecture is built for mission-critical operations broadly, the same capabilities translate directly into drone technology used in agriculture:
Together, these onboard capabilities function as the agriculture drone software layer of the system — the same real-time DOM, 3D modeling, and change-detection engine described above, applied to farmland rather than terrain or infrastructure. This makes DroneSwarm one option within broader agricultural drone solutions for operations managing large or multiple fields.
Essentially yes — the same real-time DOM, 3D modeling, and change-detection engine applies, just pointed at farmland instead of terrain or facilities. This is what makes the underlying drone technology used in agriculture here an extension rather than a separate product.
Yes, the path-planning engine supports intelligent zoning and route-overlap optimization for large or irregular farmland, using the same coverage logic as efficient drones for agricultural crop surveillance at scale. Plot size and shape do not require a different setup.
Yes — positioning combines GPS with visual SLAM rather than relying on satellite signal alone, keeping accuracy under 1×GSD even when signal quality drops. This fusion approach is what gives UAV positioning its consistency in difficult conditions.
No — when the link drops, the system switches to cached imagery and keeps processing locally, so tracking of the target continues without interruption. UAV tracking doesn't require a continuous connection to remain active.
Most project cases are covered by client confidentiality agreements, so direct examples are not shown. However, we can discuss a pilot or demo tailored to your conditions. Please contact our team with a brief description of your use case to get started.
Share your application, project environment and technical requirements.
Follow Us :

Visual spatial intelligence for mapping, reconstruction and analysis.
Copyright © 2026 ICE CYPRESS. All rights reserved.